Start from working hardware
If you want the official robot and software stack as one product, check Pollen Robotics for current MicroDuck specifications, regions and availability.
View the official MicroDuck page ↗MicroDuck alternative / Agent Core concept
MechaSeed is exploring a profile-matched hardware and software core for printable robots. The concept is at demand validation; it is not a complete robot or a verified MicroDuck-compatible kit.
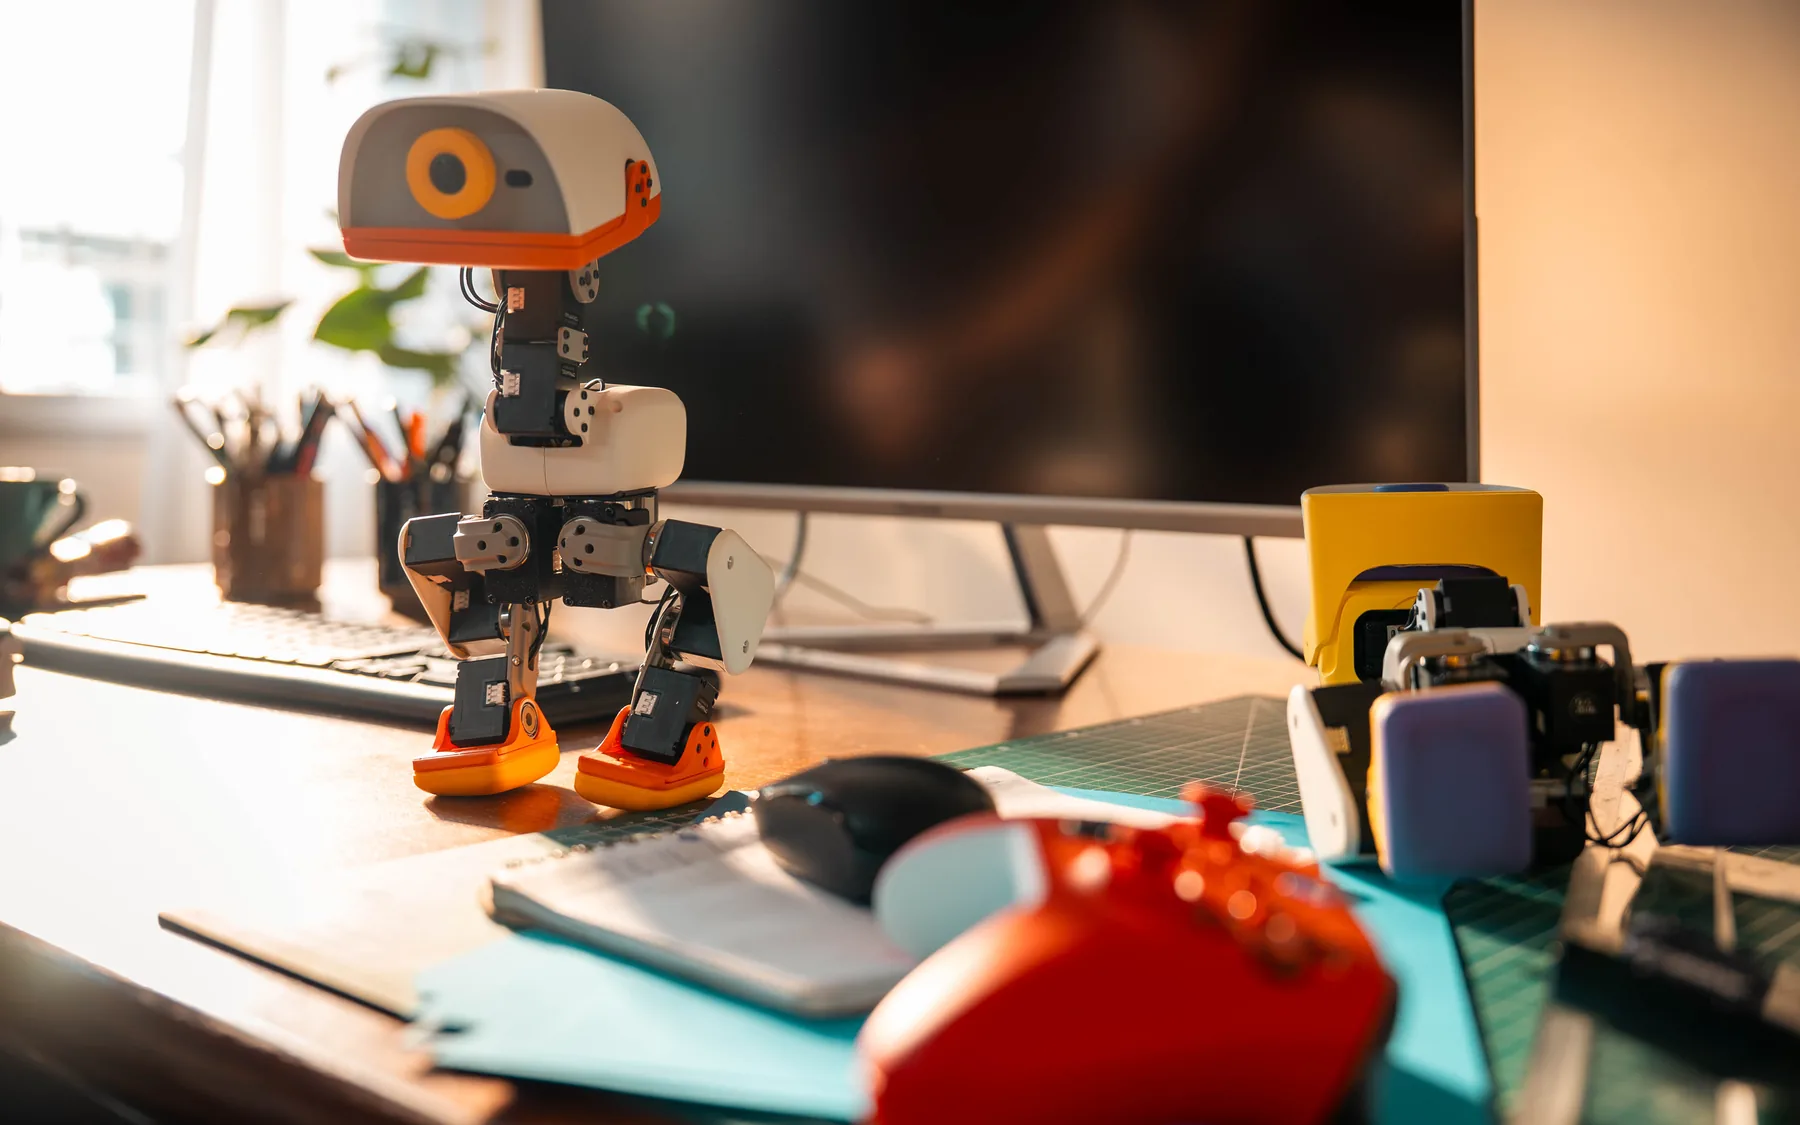
“Alternative” can mean an assembled product, a transparent DIY build or a future core that reduces integration work. Those are different needs, so each has a different next step.
If you want the official robot and software stack as one product, check Pollen Robotics for current MicroDuck specifications, regions and availability.
View the official MicroDuck page ↗If sourcing, printing, assembly and calibration are part of the project, compare MicroDuck with the public Open Duck Mini v2 build route before choosing.
Read the builder’s comparison →If a profile-matched hardware and software core would remove the most difficult sourcing and setup work, join the research waitlist.
Join the Agent Core research waitlist →A printable body solves only the visible structure. The harder repeat work is matching motion hardware, electronics, configuration, calibration and software to one exact body revision.
Target actuators, wiring, control, compute, sensing and power for a versioned Body Profile.
Map joint IDs, directions, zero offsets and sensor frames to the chosen body revision.
Provide a repeatable starting point for assembly checks and safe first movement.
Target firmware, examples and an agent-facing SDK without promising unchanged third-party code or policies.
Target value: Profile-matched Hardware + Configuration + Reference Calibration + Software Integration. See the Agent Core concept and current boundaries for the full target scope.
The Agent Core concept does not turn a third-party body into a MechaSeed product. Builders remain responsible for the design rights, printed structure, ordinary mechanical parts and final assembly.
Choose the exact design and revision you are allowed to use. Public software does not automatically make mechanical files available.
Print the body and source shells, screws, bearings and other non-core mechanical parts required by that design.
Assemble the robot, inspect wiring and mechanics, and follow the safety and calibration steps for the selected profile.
A parts-list target is not a finished-build price. Taxes, shipping, tools, failed prints, replacements and time all matter. See what an Open Duck Mini v2 build budget includes.
The useful question today is not whether the concept sounds complete, but which parts have evidence. At Stage 1, the answer is deliberately limited.
| Area | Current status | What would need validation |
|---|---|---|
| Body Profile | No supported body yet. | Revision, geometry, mounts, legal file access and assembly. |
| Hardware + calibration | Target scope only. | Actuator choices, interfaces, wiring, power, sensors and safe reference calibration. |
| SDK + policies | Proposed; no finished SDK or unchanged policy support. | APIs, timing, observation and action spaces, simulation and real hardware behavior. |
| Price | Target pricing: TBD. | Validated BOM, manufacturing, included parts and support. |
| Availability | Research waitlist only; not for sale or pre-order. | Feasibility, production scope, regions and delivery plan. |
These answers describe the current concept boundary, not future shipping specifications.
No. MechaSeed is validating an independent hardware-and-software core concept for printable robots. It does not sell a complete MicroDuck clone or distribute a MicroDuck shell.
That has not been verified. No MicroDuck Body Profile, drop-in hardware compatibility or unchanged software compatibility is currently claimed.
The target is profile-matched motion hardware, control, compute, sensing, power, configuration, reference calibration and software integration. The final hardware, SDK and delivery scope remain unverified.
No. The concept is at demand-validation stage and target pricing is TBD. The waitlist is for research and project updates, not an order, pre-order or delivery commitment.
Third-party specifications, prices and availability can change. Sources and image credits checked September 18, 2026.
Official product overview, software positioning and current offer.
Official specifications, software-versus-hardware openness boundary and source for the MicroDuck photograph used here.
Official robot software repository.
Official reinforcement-learning repository.
Public DIY hardware, build and simulation project reference.
Join the Agent Core research waitlist and tell us which printable body and development workflow you need. It is an interest registration, not an order or pre-order.